Back to projectscomputer-vision-project
ARCHIVED/ School
Computer Vision - Detection and Trajectory
START
03/25
END
04/25
TEAM
3 pers.
STATUS
ARCHIVED
01OBJECTIVES
- 01Modeling and characterization of camera
- 02Manipulation of image and video files
- 03Data extraction, from static to dynamic
- 04Create a complete project under OpenCV
02PROCESS
STEP 01
Calibration of the camera to obtain its intrinsic parameters.
STEP 02
Estimation of the interest of doing distortion compensation.
STEP 03
Determination of the homography between the camera and the scene.
STEP 04
Object detection in the scene.
STEP 05
Augmentation of the video by its centroid and bounding box
STEP 06
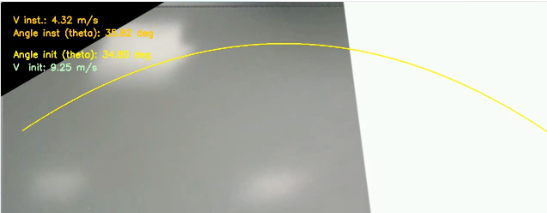
Augmentation of the video by its parabolic trajectory approximation.
STEP 07
Approximation by a simple ballistic model and deduction of the initial speed and angle parameters.
STEP 08
Projection of the model for an estimation of the future position of the balloon in the white area.
03TECHNOLOGIES USED
Python
04SKILLS
- •Python (OpenCV)
- •Computer Vision
- •Analysis of images and videos
05PROJECT MEDIA
01 / 02
06RESULTS & METRICS
- R01Detection and tracking of moving objects in videos
- R02Estimation of movement parameters (speed, angle) of detected objects
- R03Prediction of the future trajectory of detected objects